Course project · Team of 5·Mar – Apr 2026Complete
Autonomous Path-Following Robot
Discrete MOSFET H-bridge with optocoupler isolation, inductive path sensing and time-of-flight obstacle detection.
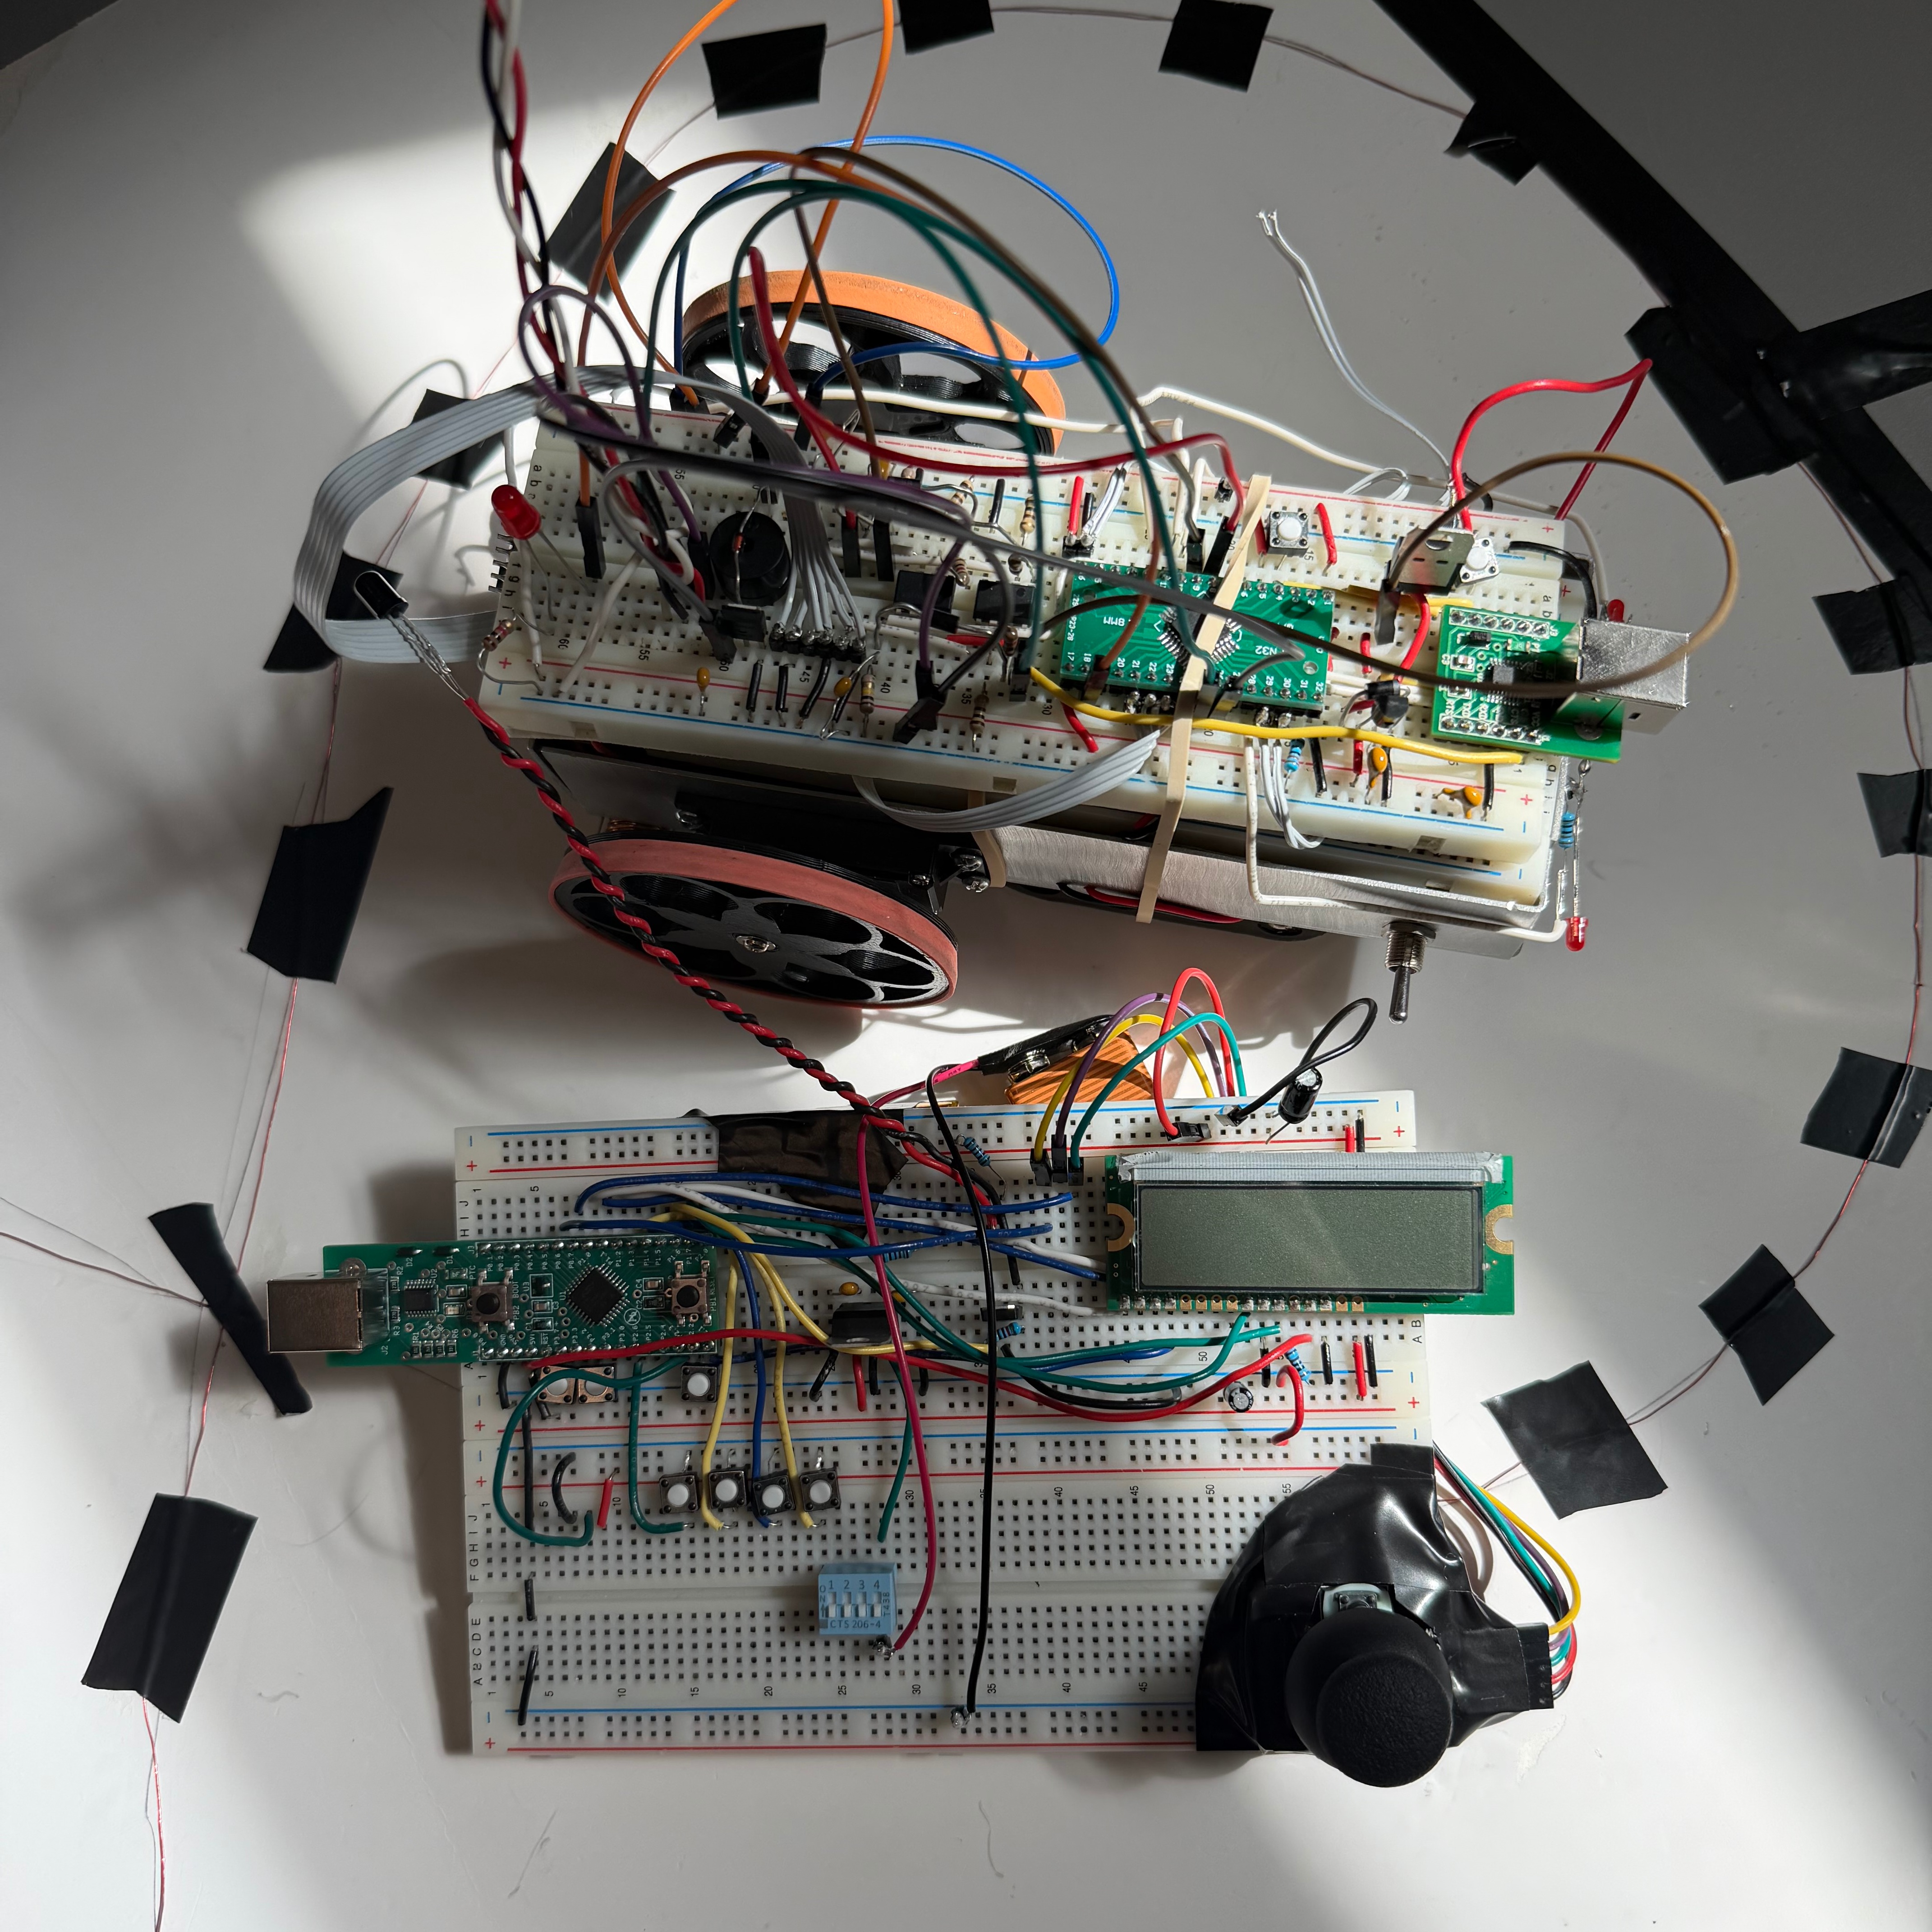
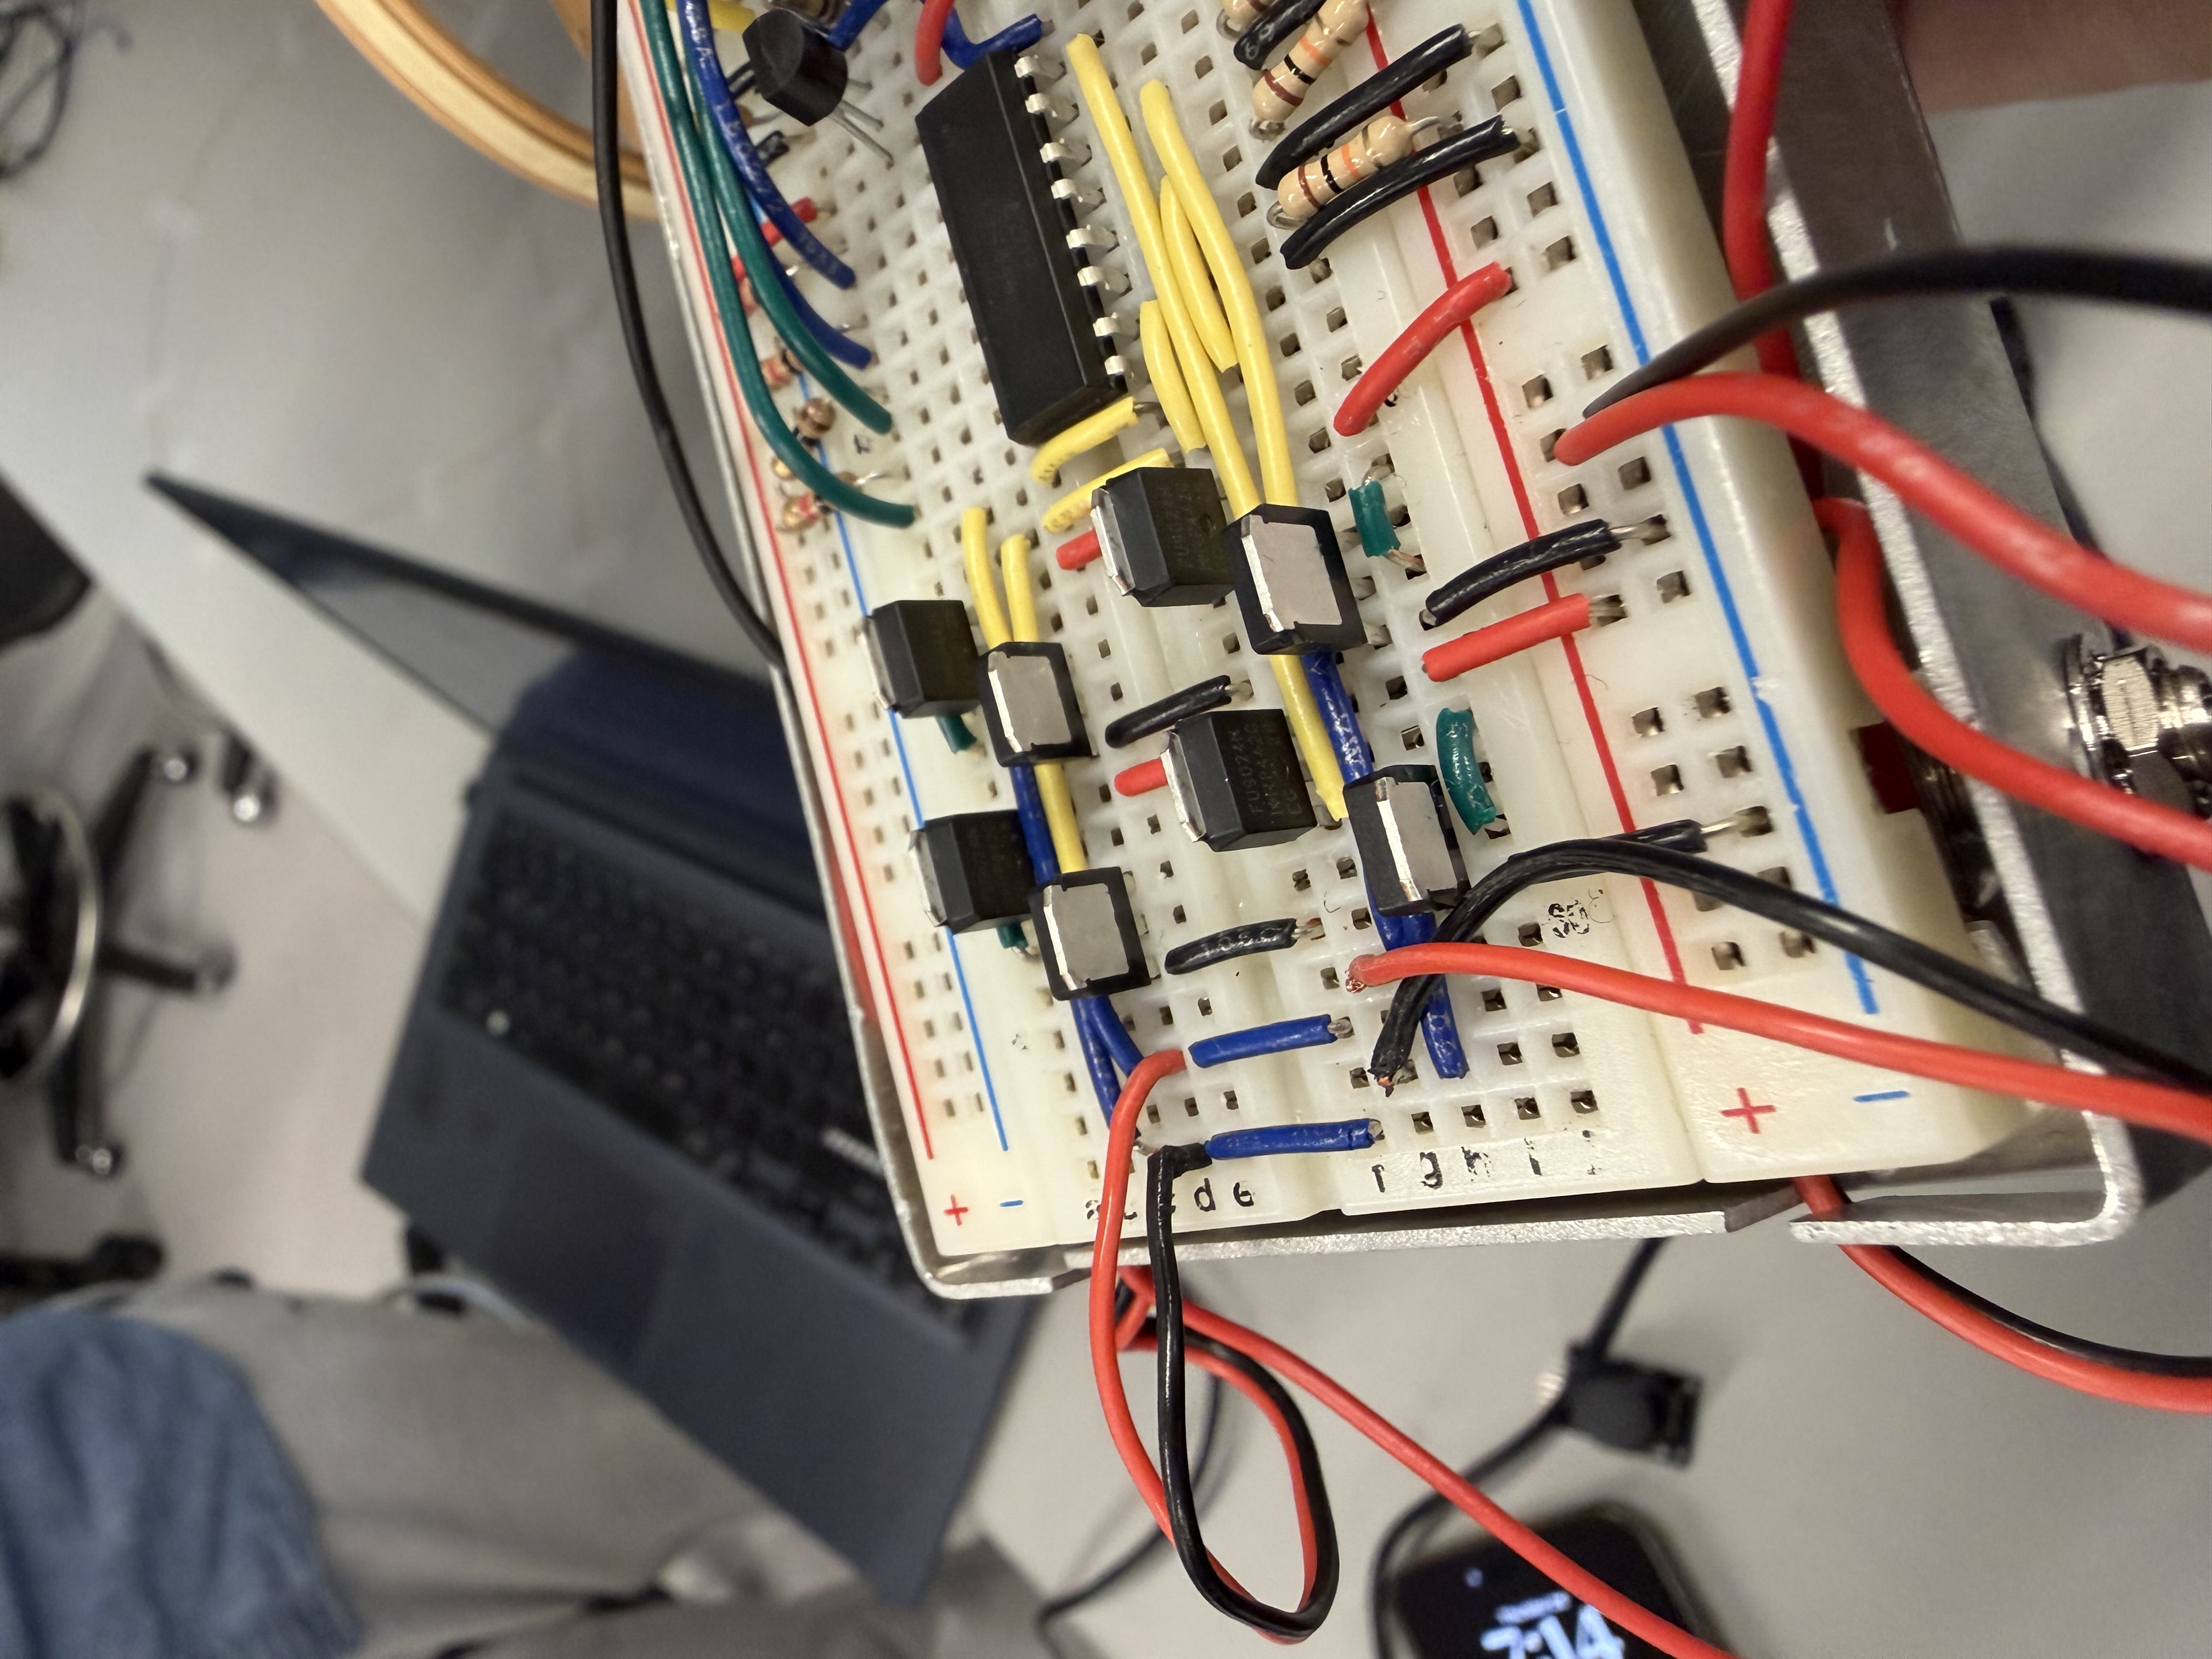
Assembled, integrated and tested a discrete MOSFET H-bridge motor driver with optocoupler isolation for bidirectional motor control. Tuned an LC tank resonant circuit for inductive path sensing so the robot could detect left, centre and right channels, and calibrated firmware thresholds in C for both remote control and autonomous path-following.
Highlights
- Bench-tested a discrete MOSFET H-bridge with optocoupler isolation between logic and motor power stages
- VL53L0X time-of-flight obstacle detection over I2C with a 6 cm auto-stop: collision-free across 5 consecutive runs
- Sensor bias compensation and turn thresholds in C for 35 successful intersection maneuvers over 5 runs